Research applications
The supplied material describes SLAM, path planning, and vision-based grasping research. Contact Senfar to confirm the configuration and technical specifications.
Complete Robots
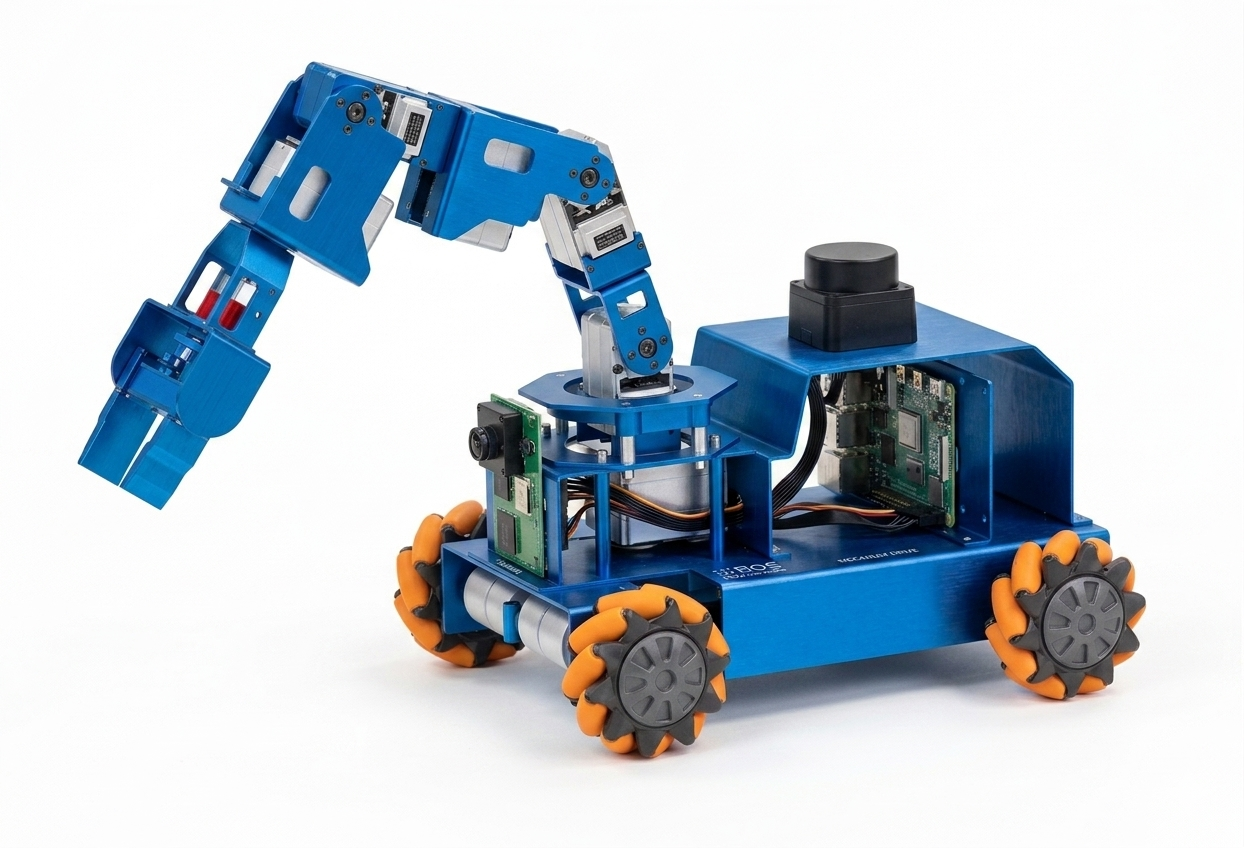
SFER100 Research Mobile Manipulator
An integrated mobile manipulator combining mecanum wheels, onboard sensing, and a robotic arm for university robotics research.
Product overview
Accelerate your robotics research with a fully integrated mobile manipulator. Featuring agile mecanum wheels, an onboard sensor suite, and a versatile robotic arm, this is the perfect hardware for university labs to develop and test complex ROS algorithms, including SLAM, path planning, and vision-based grasping.
The supplied material describes SLAM, path planning, and vision-based grasping research. Contact Senfar to confirm the configuration and technical specifications.
Technical specification
Published values describe the listed configuration. Confirm the final model, interfaces, and operating limits with engineering before selection.
Product media
Explore product images and demonstration footage from the supplied materials.
Product resources
Engineering support
Discuss SFER100 configuration, pricing, or integration needs. Request drawings, protocols, and SDK details from our team.